
koala73/worldmonitorConnectors
Real-time global intelligence dashboard. AI-powered news aggregation, geopolitical monitoring, and infrastructure tracking in a unified situational awareness interface
86k
ROS MCP Server sits between an MCP client and a ROS or ROS2 robot. It gives the agent a way to discover topics, services, actions, parameters, and sensor data, then send commands back to the robot.
Builders who want their agent to talk to a robot through ROS or ROS2.
You can control and inspect a robot from an MCP-capable agent without changing the robot’s source code.
The server lets an agent both send commands to the robot and read what the robot is doing.
It can publish and subscribe to topics, call services and actions, set parameters, and read sensor and state data.
It helps the agent discover available ROS topics, services, actions, and custom message types so it can use the right syntax.
It works with Claude Code, Codex CLI, Gemini CLI, Claude Desktop, ChatGPT, Cursor, and other MCP clients.
The server is built to work across ROS 1 distros and ROS 2 releases such as Humble and Jazzy.





ROS-MCP-Server connects large language models (such as Claude, GPT, and Gemini) to robots, enabling bidirectional communication with no changes to existing robot source code.
rosbridge node to your existing ROS setup.

🏭 Example - AI Agent diagnosis of Industrial Robot End Effector (Video)

🤖 Example - Controlling "Wilson" with natural language (video)
From a single prompt — "Grab a Coke from the fridge & go to the living room." — Google Gemini uses the MCP server to navigate and manipulate autonomously. Built on ROS 2 with Nav2 (SLAM) for mapping and navigation, and MoveIt to command the manipulator.

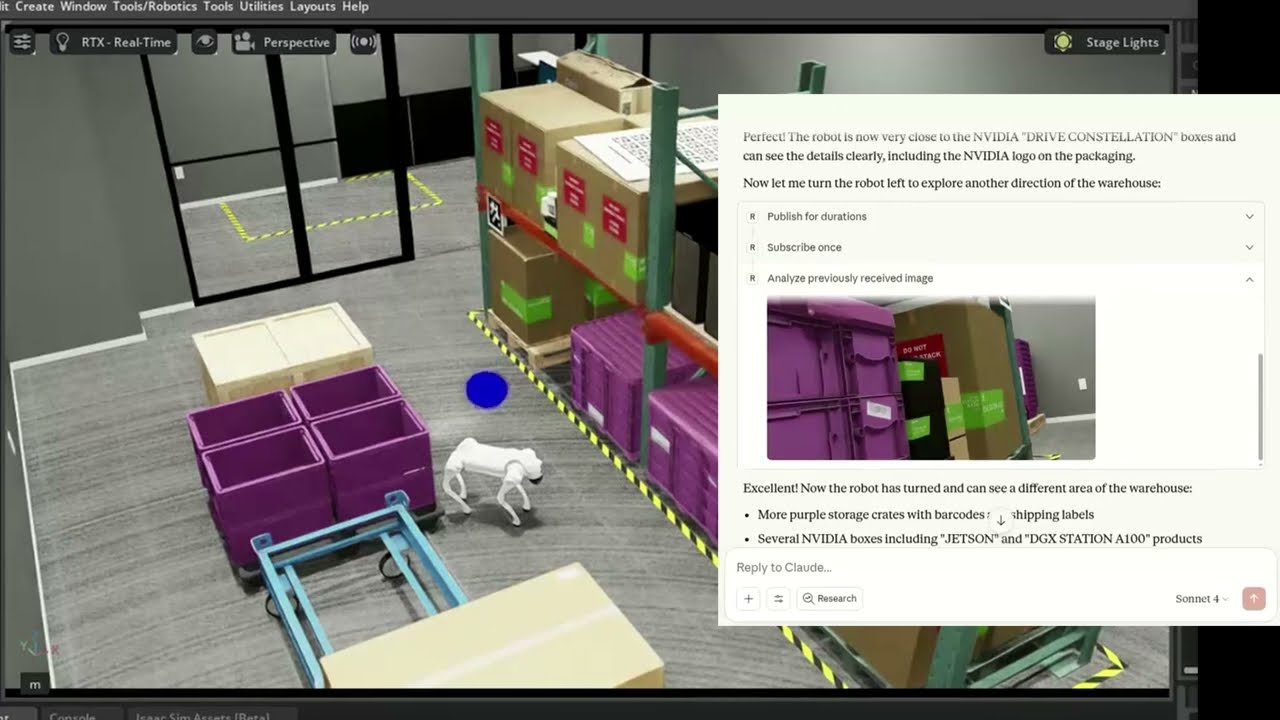
🐕 Example - Controlling Unitree Go2 in NVIDIA Isaac Sim (video)
The MCP server connects Claude to a simulated Unitree Go2 quadruped in NVIDIA Isaac Sim, interpreting natural language commands to navigate and control the robot.
Follow the installation guide to get started.
ROS-MCP works with Claude Code, Codex CLI, Gemini CLI, Claude Desktop, ChatGPT, Cursor, or any MCP-compatible client.

Browse our examples to see the server in action.
We welcome community PRs with new examples and integrations!
We love contributions of all kinds:
Check out the contributing guidelines and see issues tagged good first issue to get started.
This project is licensed under the Apache License 2.0.
Sign in to join the discussion.
No comments yet. Be the first to say what this is good for.
Real-time global intelligence dashboard. AI-powered news aggregation, geopolitical monitoring, and infrastructure tracking in a unified situational awareness interface
High-performance code intelligence MCP server. Indexes codebases into a persistent knowledge graph — average repo in milliseconds. 158 languages, sub-ms queries, 99% fewer tokens. Single static binary, zero dependencies.

Universal provider proxy for OpenAI Codex & Claude Code — use any LLM (Claude, Gemini, Grok, DeepSeek, Ollama…) with Codex CLI, App, SDK, and Claude Code

Git-native persistent memory for AI coding agents. Implements Google OKF v0.2 with sub-300µs in-memory BM25 search, embedded MCP server, and progressive disclosure. Slashes token bloat by 80% with zero external databases or dependencies. Built in pure Go.

Local-first code intelligence graph for MCP and CLI. Builds a persistent map of your codebase so AI coding tools read only what matters, with benchmarked context reductions on reviews and large-repo workflows.

Stop your AI from making things up — it proposes, deterministic tools decide, every claim checked against ground truth with evidence. Grounded facts and context survive resets. Reverse engineering is the proving ground. MCP server + CLI.